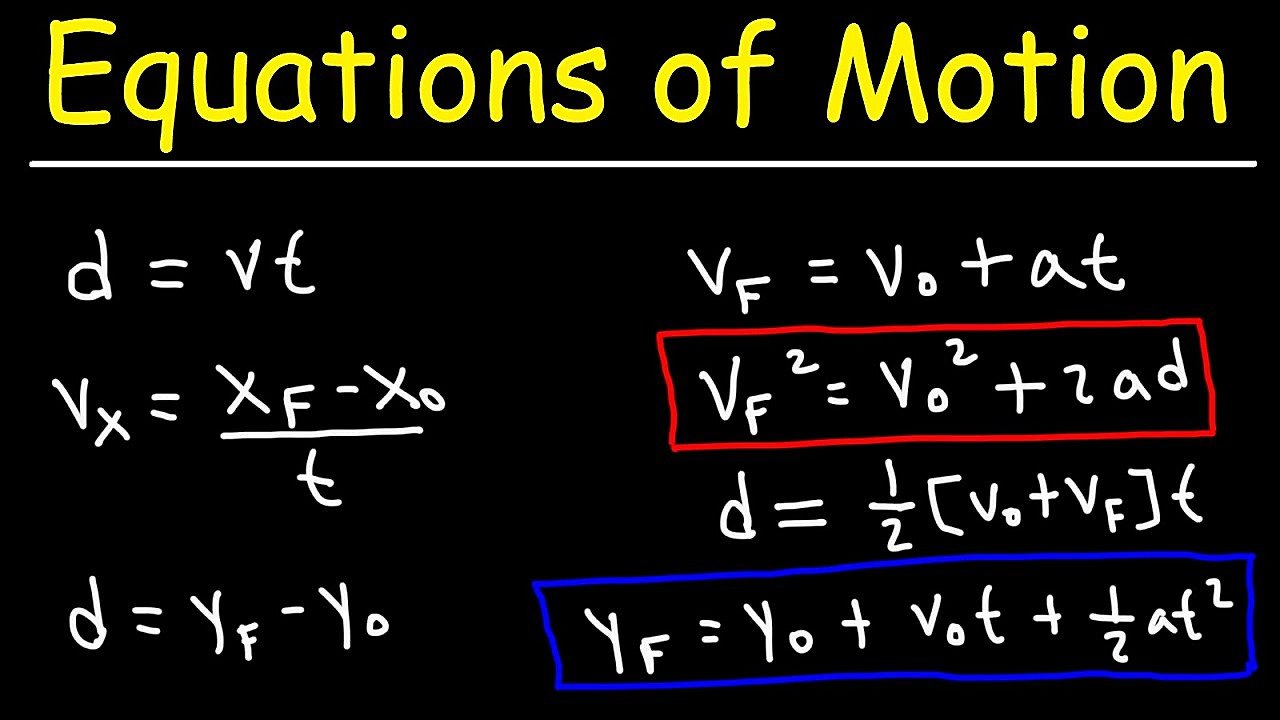
The equation of motion for simple harmonic motion (SHM) is d²x/dt² = −ω²x, and its solution is x(t) = A cos(ωt + φ). The equation states that acceleration is proportional to displacement and acts opposite to it.
For a reliable reference, consult OpenStax University Physics Volume 1.
What Is the Equation of Motion for Simple Harmonic Motion?
The equation of motion for SHM is the differential equation d²x/dt² = −ω²x. For a mass on a spring, ω² equals k/m, where k is the force constant and m is the mass. The table below shows 3 forms of the equation.
| Form | Equation | Meaning |
|---|---|---|
| Newton's second law form | m d²x/dt² = −kx | Net force equals the spring force |
| Standard form | d²x/dt² = −ω²x | Acceleration is proportional to displacement and opposite to it |
| Solution | x(t) = A cos(ωt + φ) | Displacement varies sinusoidally with time |
Sources: OpenStax University Physics Volume 1 and AQA A-level physics notes.
What Is Simple Harmonic Motion?
Simple harmonic motion is oscillatory motion in which the restoring force is proportional to the displacement and acts opposite to the displacement. Examples include a mass on a spring and a simple pendulum at small amplitude.
What Are the Conditions for SHM?
SHM requires 3 conditions:
- A restoring force proportional to displacement
- A force directed toward the equilibrium position
- Negligible damping from friction
How Is the Equation of Motion for SHM Derived?
Combine Hooke's law with Newton's second law to get m d²x/dt² = −kx. The derivation uses 5 steps:
- Write Hooke's law: Fₓ = −kx.
- Apply Newton's second law: ma = −kx.
- Replace a with d²x/dt²: m d²x/dt² = −kx.
- Divide by m: d²x/dt² = −(k/m)x = −ω²x.
- Substitute x = A cos(ωt + φ) to confirm that ω² = k/m.
What Is the Solution to the SHM Equation?
The solution is x(t) = A cos(ωt + φ). Sine and cosine differ only by a phase shift, so either function models SHM. The table below defines the 5 symbols.
| Symbol | Quantity | SI Unit |
|---|---|---|
| x | Displacement from equilibrium | m |
| A | Amplitude (maximum displacement) | m |
| ω | Angular frequency, equal to 2π/T or 2πf | rad/s |
| φ | Phase shift | rad |
| t | Time | s |
The same source defines angular frequency as ω = 2π/T = 2πf.
What Is the Difference Between the Sine and Cosine Forms?
The cosine form x = A cos ωt starts at maximum displacement, and the sine form x = A sin ωt starts at equilibrium. Because sin θ = cos(θ − π/2), the sine form equals the general cosine form with φ = −π/2.
How Is the Phase Constant Found?
Find φ from the initial conditions, using x(0) = A cos φ and v(0) = −Aω sin φ. The table below lists 4 initial conditions and the matching phase constant.
| Initial Condition | cos φ | sin φ | Phase Constant φ |
|---|---|---|---|
| x(0) = A, v(0) = 0 | 1 | 0 | 0 |
| x(0) = 0, v(0) > 0 | 0 | −1 | −π/2 |
| x(0) = −A, v(0) = 0 | −1 | 0 | π |
| x(0) = 0, v(0) < 0 | 0 | 1 | +π/2 |
What Are the Velocity and Acceleration Equations in SHM?
Differentiate the position equation to get v(t) = −Aω sin(ωt + φ), and differentiate again to get a(t) = −Aω² cos(ωt + φ). The velocity has a maximum magnitude of Aω, and the acceleration has a maximum magnitude of Aω². The table below shows each equation with its maximum.
| Quantity | Equation | Maximum Magnitude | Occurs At |
|---|---|---|---|
| Displacement | x = A cos(ωt + φ) | A | Turning points, x = ±A |
| Velocity | v = −Aω sin(ωt + φ) | Aω | Equilibrium, x = 0 |
| Acceleration | a = −Aω² cos(ωt + φ) | Aω² | Turning points, x = ±A |
Three relationships link the quantities directly:
- a = −ω²x
- v = ±ω√(A² − x²)
- v_max = ωA
What Are the Phase Relationships in SHM?
Velocity leads displacement by π/2 rad, and acceleration is in antiphase with displacement. The identities −sin θ = cos(θ + π/2) and −cos θ = cos(θ + π) give v = Aω cos(ωt + φ + π/2) and a = Aω² cos(ωt + φ + π).
What Are the Period and Frequency Formulas for SHM Systems?
The period of a mass on a spring is T = 2π√(m/k), and the angular frequency is ω = √(k/m). The table below lists the formulas for 4 systems.
| System | Angular Frequency (ω) | Period (T) | Variables |
|---|---|---|---|
| Mass on a spring | √(k/m) | 2π√(m/k) | m = mass, k = force constant |
| Simple pendulum | √(g/L) | 2π√(L/g) | L = length, g = gravitational acceleration |
| Physical pendulum | √(mgL/I) | 2π√(I/(mgL)) | I = moment of inertia, L = pivot to center of mass distance |
| Torsional pendulum | √(κ/I) | 2π√(I/κ) | κ = torsional constant, I = moment of inertia |
A simple pendulum undergoes SHM for amplitudes less than about 15°.
Does Amplitude Affect the Period of SHM?
No. The period of SHM is independent of amplitude. Only the mass and the force constant affect the period of a mass on a spring. The OCR A specification calls such an oscillator isochronous.
How Does Gravity Affect a Vertical Spring?
Gravity shifts the equilibrium position and leaves the SHM equation unchanged. A block on a vertical spring still obeys m d²y/dt² = −ky, measured from the new equilibrium.
What Is the Energy Equation in SHM?
The total energy is E = ½kx² + ½mv² = ½kA², and it stays constant. The velocity follows from energy as v = ±√((k/m)(A² − x²)). The table below shows the energy split at 4 positions.
| Position | Potential Energy (fraction of E) | Kinetic Energy (fraction of E) |
|---|---|---|
| x = ±A | 1 | 0 |
| x = ±0.707A | 1/2 | 1/2 |
| x = ±A/2 | 1/4 | 3/4 |
| x = 0 | 0 | 1 |
What Are Worked Examples of the SHM Equation of Motion?
There are 4 worked examples. Examples 1 to 3 use a 0.500 kg block on a spring with k = 50.0 N/m. The block is released from rest at x = +0.0800 m, so φ = 0.
How Are the Equations of Motion Written for a Mass on a Spring?
- Angular frequency: ω = √(k/m) = √(50.0/0.500) = 10.0 rad/s
- Period: T = 2π/ω = 0.628 s
- Maximum velocity: v_max = Aω = 0.0800 × 10.0 = 0.800 m/s
- Maximum acceleration: a_max = Aω² = 0.0800 × 100 = 8.00 m/s²
- Equations: x = 0.0800 cos(10.0t) m, v = −0.800 sin(10.0t) m/s, a = −8.00 cos(10.0t) m/s²
How Are Position, Velocity, and Acceleration Found at a Given Time?
At t = 0.100 s, the phase is ωt = 1.00 rad. The calculator must be in radians mode.
- Position: x = 0.0800 cos(1.00) = 0.0432 m
- Velocity: v = −0.800 sin(1.00) = −0.673 m/s
- Acceleration: a = −8.00 cos(1.00) = −4.32 m/s²
- Check: a = −ω²x = −100 × 0.0432 = −4.32 m/s²
How Is Speed Found at a Given Displacement?
At x = 0.0400 m, the speed follows from v = ω√(A² − x²).
- Speed: v = 10.0 × √(0.0800² − 0.0400²) = 10.0 × √0.0048 = 0.693 m/s
- Energy check: E = ½kA² = 0.160 J, PE = ½kx² = 0.040 J, KE = 0.120 J, and v = √(2 × 0.120/0.500) = 0.693 m/s
How Is the Period of a Simple Pendulum Calculated?
A simple pendulum with L = 1.00 m uses g = 9.80 m/s².
- Angular frequency: ω = √(g/L) = √9.80 = 3.13 rad/s
- Period: T = 2π√(L/g) = 2π × 0.319 = 2.01 s
- Frequency: f = 1/T = 0.498 Hz
What Are the Damped and Forced Versions of the Equation of Motion?
Damping adds a −b dx/dt term, and forcing adds a F₀ sin(ωt) term. The table below compares the 3 equations. A periodic force at the natural frequency produces resonance.
| Oscillator | Equation of Motion | Solution |
|---|---|---|
| Undamped (SHM) | m d²x/dt² + kx = 0 | x = A cos(ωt + φ) |
| Damped | m d²x/dt² + b dx/dt + kx = 0 | x = A₀e^(−bt/2m) cos(ωt + φ), with ω = √(ω₀² − (b/2m)²) |
| Forced and damped | m d²x/dt² + b dx/dt + kx = F₀ sin(ωt) | x = A cos(ωt + φ), with A = F₀ / √(m²(ω² − ω₀²)² + b²ω²) |
What Is the Difference Between University Physics and A-Level Notation for SHM?
A-level courses define SHM with a = −ω²x, and university physics texts start from m d²x/dt² = −kx. The OCR A specification lists a = −ω²x, the solutions x = A cos ωt or x = A sin ωt, and v = ±ω√(A² − x²). The table below compares the 2 notations.
| Concept | University Physics | A-Level (UK) |
|---|---|---|
| Defining equation | d²x/dt² = −(k/m)x | a = −ω²x |
| Position | x = A cos(ωt + φ) | x = A cos ωt or x = A sin ωt |
| Velocity from position | v = ±√((k/m)(A² − x²)) | v = ±ω√(A² − x²) |
| Maximum velocity | v_max = Aω | v_max = ωA |
What Mistakes Do Students Make With SHM Equations?
Students make the most errors with frequency, amplitude, and the direction of acceleration. The table below lists 3 studies.
| Study | Sample | Finding |
|---|---|---|
| Tumanggor et al., 2020 | 60 grade 10 students | 40.7% held misconceptions and 36.4% understood the concepts, with the largest misconception rate (75%) on the frequency of SHM |
| Ambrose, PERC studies | Introductory physics students | A persistent intuition links larger amplitude to a longer period |
| Wiyanto | 30 second-year physics teacher students | All failed to draw the acceleration direction of a pendulum, and 50% confused the definition of acceleration |
The table below lists 5 common errors and their corrections.
| Error | Correct Practice |
|---|---|
| Using degrees mode on the calculator | Use radians mode |
| Expecting the period to grow with amplitude | Treat the period as independent of amplitude |
| Dropping the minus sign in a = −ω²x | Keep the sign, so acceleration points toward equilibrium |
| Mixing f and ω | Convert with ω = 2πf |
| Applying the pendulum formula at large amplitude | Keep the amplitude below about 15° |
People Also Ask
What Is the General Equation of SHM?
The general equation is x(t) = A cos(ωt + φ).
What Is the Differential Equation for SHM?
The differential equation is d²x/dt² = −ω²x, which equals d²x/dt² = −(k/m)x for a mass on a spring.
What Is the Acceleration at Maximum Displacement?
The acceleration has its maximum magnitude Aω² at x = ±A, directed toward equilibrium.
What Is the Velocity at the Equilibrium Position?
The velocity at equilibrium has its maximum magnitude, v_max = Aω.
Is a Simple Pendulum a Case of SHM?
Yes, a simple pendulum undergoes SHM for amplitudes less than about 15°.
How Do You Convert Frequency to Angular Frequency?
Multiply the frequency by 2π, because ω = 2πf.
What Is the Summary of the Equation of Motion for SHM?
The equation of motion for SHM is d²x/dt² = −ω²x, with the solution x(t) = A cos(ωt + φ). Here are 6 key facts:
- States acceleration as a = −ω²x
- Solves to x = A cos(ωt + φ)
- Derives v = −Aω sin(ωt + φ) and a = −Aω² cos(ωt + φ)
- Sets ω = √(k/m) for a spring and ω = √(g/L) for a simple pendulum
- Conserves total energy at E = ½kA²
- Keeps the period independent of amplitude
The University of the West Indies
My passion as a teacher and leader in education is to contribute to students’ enhanced learning by creation of a positive teaching/learning environment, where they are motivated to develop strong critical thinking, analytical and problem-solving skills.
As acting Vice-Principal and head of Physics, I have amassed five years of experience in leading meetings, implementing strategies to maintain discipline and school ethos, liaise with stakeholders in planning for future development of the institution; successfully negotiated the implementation of various projects for student development as well as supervising effective execution of such. For the past 19 years, I have incorporated discovery learning within the classroom through practical activities, problem solving and cooperative learning and have realized that students retention in Physics and Mathematics have increased significantly.
I am always cognizant that students have different learning styles, and as such teaching strategies during planning and delivery must take this crucial factor into consideration and be tailored to meet such differences.